Object Detection & Tracking on Zynq
An embedded-vision study taking object detection from MATLAB and OpenCV prototypes to an HLS core integrated on a Zynq platform.
Undergraduate embedded-vision research and implementation
What stands out.
- MATLAB & C++ algorithm prototypes
- HLS core & board integration
- Three-implementation timing demonstration
From the problem to the implementation.
The problem
Explore an implementation path for image processing that combines programmable logic with software-controlled interfaces.
The approach
- Developed the algorithm in MATLAB and C++/OpenCV.
- Created a processing core through the HLS workflow.
- Integrated the design with Vivado and Xilinx SDK on the Zynq board.
What came together
An embedded-vision implementation workflow with a system concept diagram, original demonstrations and a Persian research report.
Inside the project
2 images
Enlarge image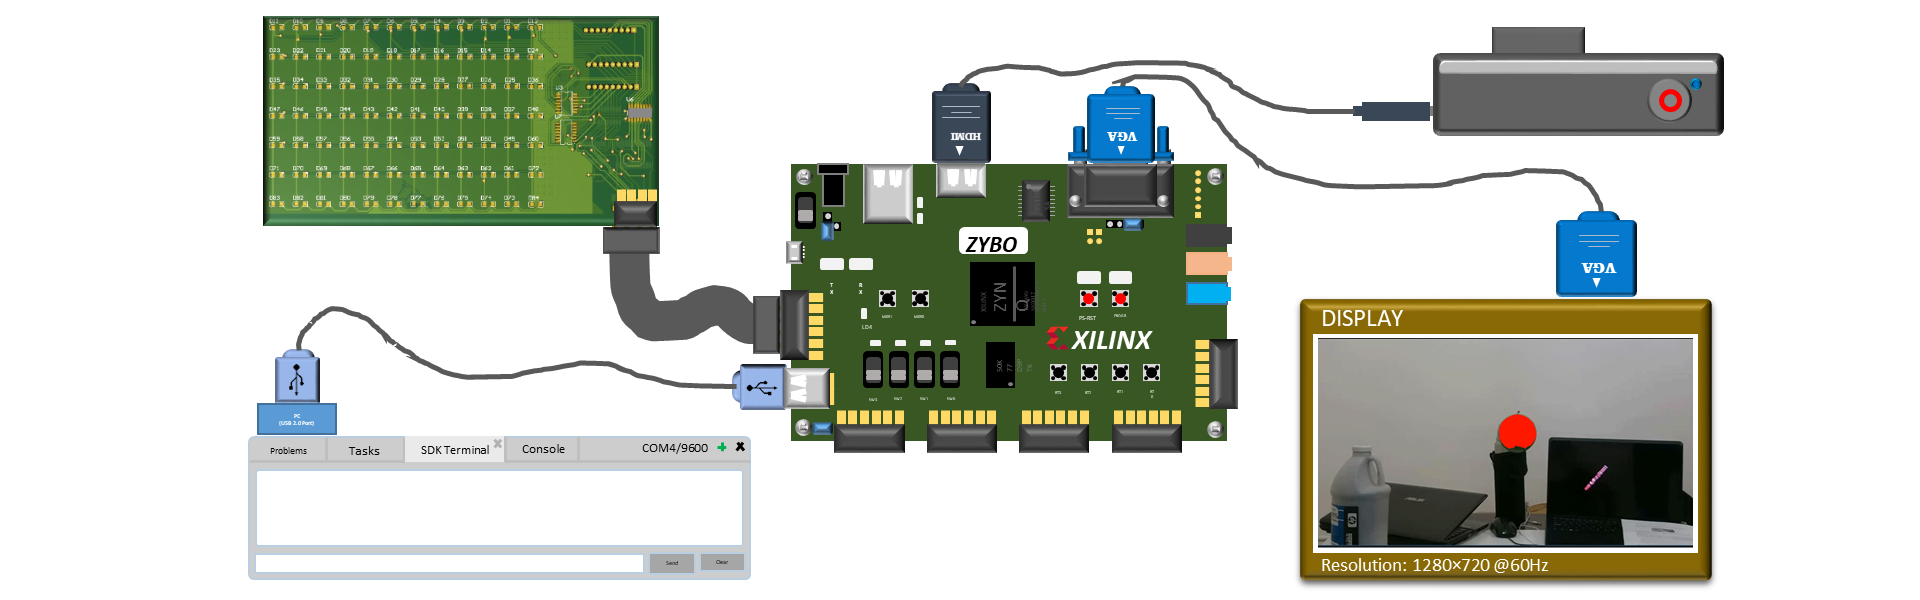 Enlarge image
See it in action
Sobel filter demonstration
Sobel-filter demonstration from the embedded-vision archive. Silent demonstration.
Open videoTarget-colour frame search
Frame-search illustration of target-colour detection. Silent demonstration.
Open videoImplementation timing comparison
Side-by-side timing comparison of three implementations. Silent demonstration.
Open videoHow the system works
Select a block to explore its role.
A guided illustration of the system components.
Camera/frame input
Video frames enter the embedded-vision path.
Target-colour logic
Pixel values are compared with a chosen colour range.
Software prototypes
MATLAB and C++/OpenCV versions establish the algorithmic workflow.
HLS core
The processing logic is expressed through the HLS development flow.
Zynq integration
Vivado and Xilinx SDK connect the core with the board-level design.
Visual output
The display shows the processed frame and marked target.
The detail behind the build
A vision algorithm on an embedded platform
My undergraduate work explored object detection and tracking on a Zynq-based platform. The project connects image-processing software with the tools needed to build and integrate programmable logic.
From software to an HLS core
The development path began with MATLAB, continued with a C++/OpenCV implementation and then moved into HLS. Vivado and Xilinx SDK were used to transfer the design into the board-level workflow.
Finding a target colour
For the colour-based detection step, pixels in an incoming frame are compared with a selected colour range and matching locations are marked. The frame-search demonstration makes this operation visible.
The board-level system
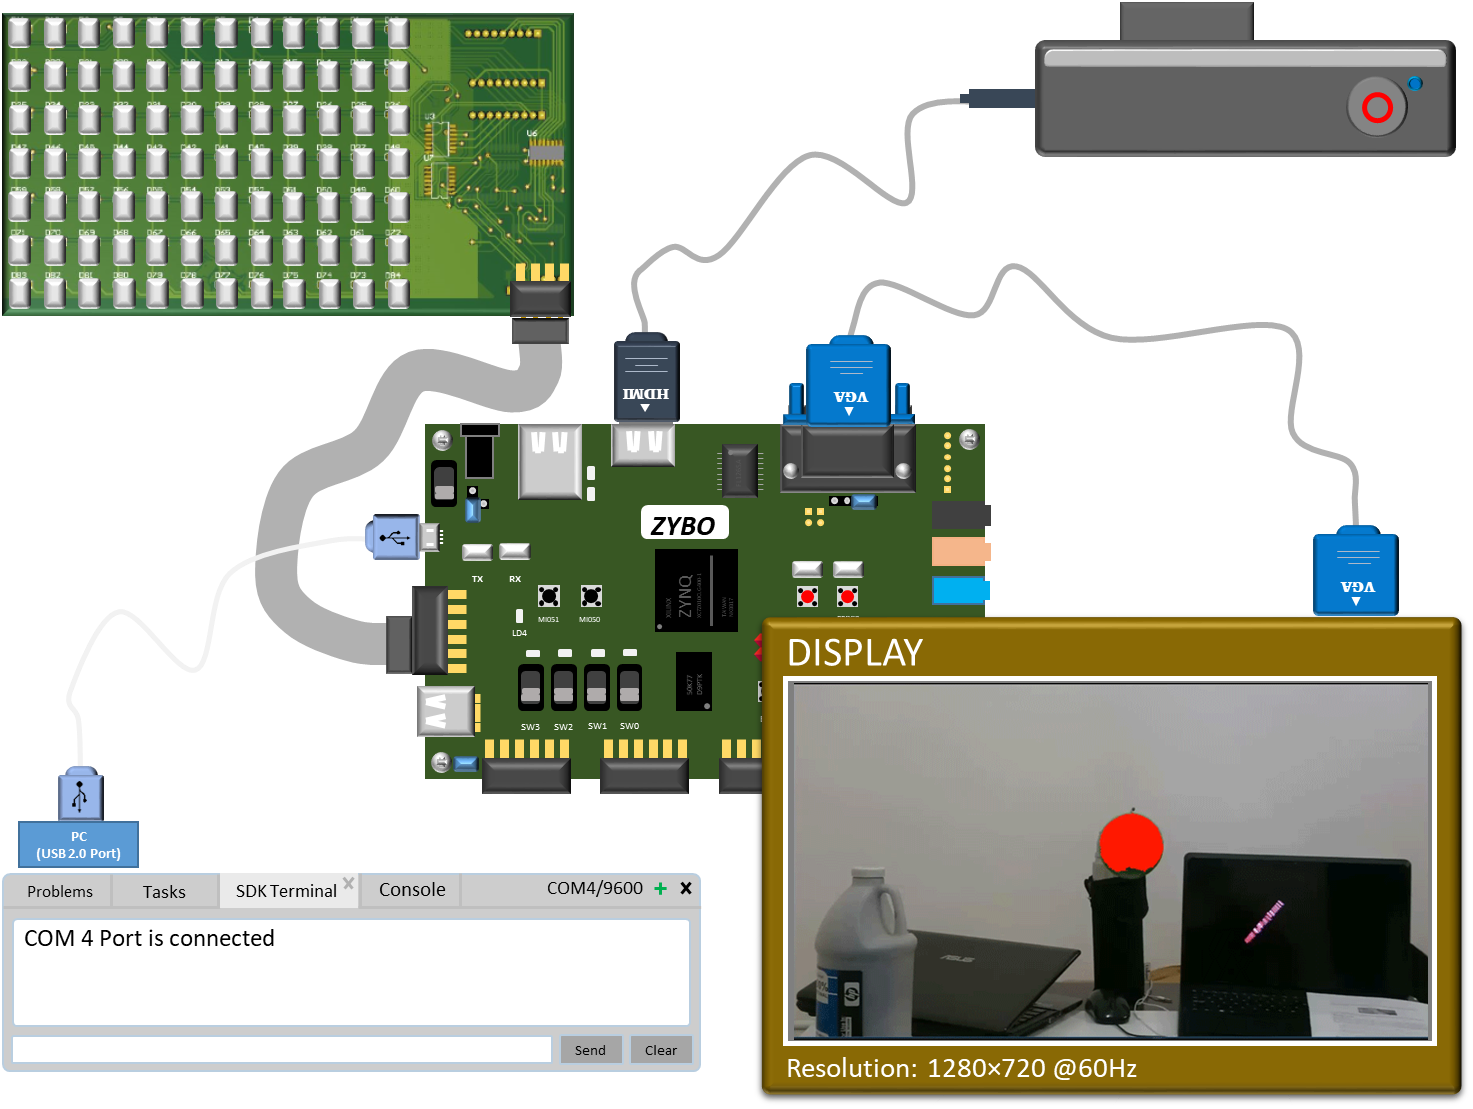
The concept diagram connects the camera/video path, ZYBO board, display and host interface. The platform uses a Zynq XC7Z010CLG400-1; the research also considered Spartan-6 and Raspberry Pi implementation options.
Different implementations, one question
The comparison recording presents the timing of three implementations side by side. The additional Sobel-filter and frame-search demonstrations show related parts of the vision-development process. Source code and the complete Persian report provide a route into the technical work.
Software, hardware & tools.
Software
- MATLAB & C++ algorithm development
- Vivado HLS, Vivado & Xilinx SDK
Hardware
- Zynq XC7Z010CLG400-1 / ZYBO
- Camera/video interface
- Display
- Host connection
- Spartan-6 and Raspberry Pi as comparison platforms
Technology stack
- Zynq
- HLS
- Embedded vision
Working on a related challenge?
Get in touch about Python, embedded systems or a research opportunity.
Aerial Object Tracking
Computer vision